Resources

Magnetic Gripper Buyer Resources

Selection guides for integrators, OEM builders, and manufacturing teams comparing magnetic grippers, magnetic EOAT, and custom robot tooling.

These resources are written as buyer-side decision aids. Use them to prepare supplier questions, compare gripper types, define validation gates, and avoid quote loops caused by missing workpiece or robot-interface data.

How to Use the Resource Library

Start with the guide closest to your current project risk. A buyer comparing robot brands needs different questions than a buyer deciding between magnetic and vacuum gripping. Each guide converts common search intent into RFQ inputs, validation checks, and internal review actions.

Buyer SituationBest ResourceDecision Output
Cobot cell needs compact steel-part grippingCobot gripper selection guidePayload, flange, cable route, release behavior, and validation checklist.
ABB robot cell requires magnetic EOAT reviewABB gripper integration guideFlange, tool data, I/O, payload, RobotStudio planning, and supplier RFQ inputs.
Project is ready for supplier quotationContact / RFQWorkpiece data, robot interface, quantity, destination, and validation assumptions sent in one inquiry.
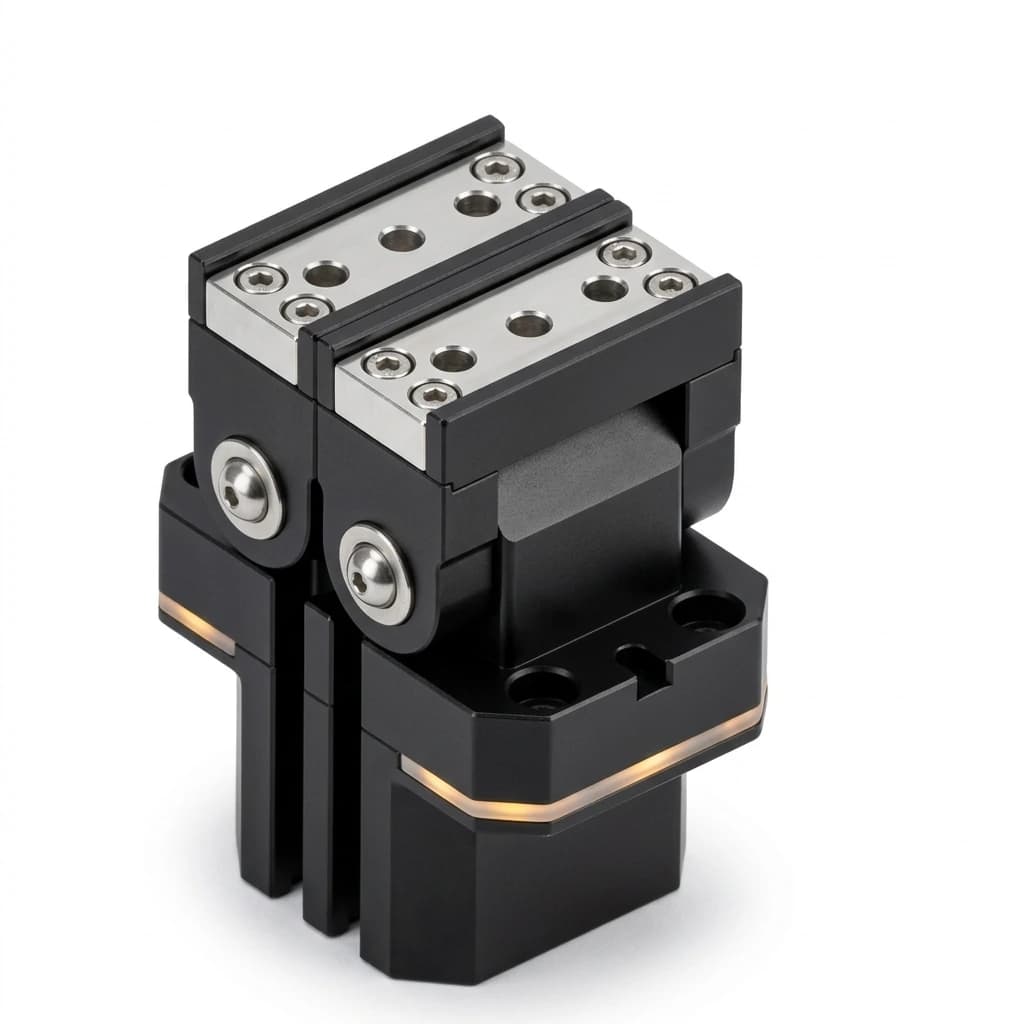
Compact magnetic gripper tooling for cobot handling

cobot gripper

Cobot Gripper Selection Guide for Magnetic EOAT

A practical guide for deciding when a magnetic cobot gripper fits ferromagnetic part handling, what to validate before quotation, and what to send for OEM review.

Robot integrators, manufacturing engineers, and OEM equipment builders using collaborative robots for ferromagnetic workpieces.

  • Best for ferromagnetic parts where compact tooling, simple pickup, and low moving mass matter.
  • Not a universal replacement for vacuum, soft, or finger grippers; material, air gap, coating, and release behavior decide fit.
  • OEM review should include robot model, flange, payload margin, workpiece data, cable route, and validation criteria.
Read guide
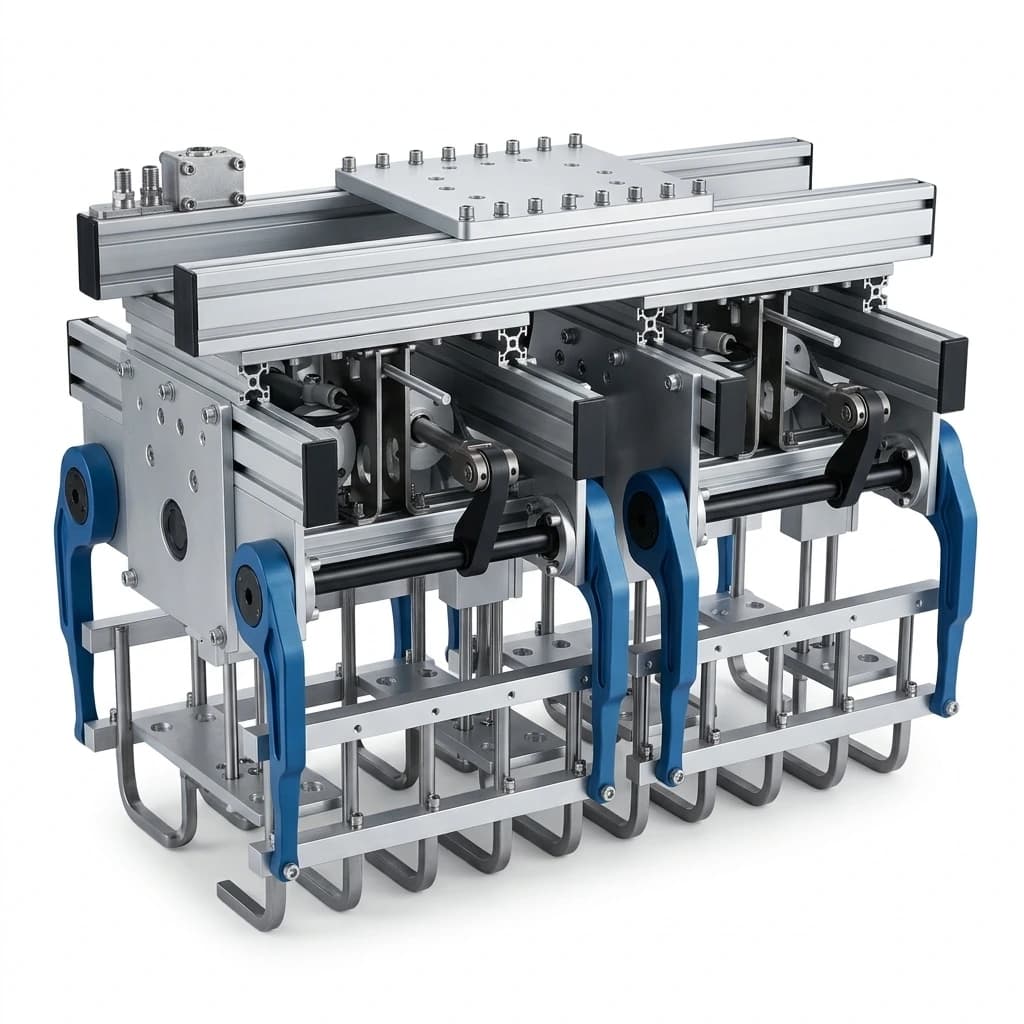
ABB GoFa CRB 15000 collaborative robot magnetic gripper kit tooling assembly

abb gripper

ABB Gripper Integration Guide for Magnetic EOAT

A practical checklist for specifying magnetic grippers on ABB industrial or collaborative robots, covering flange, payload, tool data, I/O, RobotStudio planning, and RFQ inputs for custom EOAT review.

Robot integrators, manufacturing engineers, and OEM equipment builders using ABB IRB, GoFa, SWIFTI, or other ABB robot platforms for ferromagnetic part handling.

  • Best used as an ABB robot gripper review checklist, not as a claim that every magnetic EOAT is an official ABB accessory.
  • Useful when the ABB cell handles ferromagnetic workpieces and needs a custom adapter plate, cable route, I/O plan, or release sequence.
  • RFQ review should include robot model, controller, flange, payload margin, tool center, workpiece data, cycle target, and validation criteria.
Read guide
What Makes a Useful Buyer Guide

  • It states when magnetic gripping is a poor fit, not only when it works.
  • It separates catalog assumptions from real workpiece validation.
  • It gives procurement teams a concrete RFQ checklist and acceptance-gate language.
  • It links back to product, solution, OEM, and contact pages so the buyer can move from research to quotation.

When to Contact Us

Contact our sales engineering team when your team has workpiece photos or drawings, robot model, target cycle, release requirement, and quantity direction. If your project is still early, send the uncertain items as assumptions so we can mark what requires sample validation.

  • Workpiece fit or gripper type is uncertain.
  • Payload, flange, cable, or control interface needs review.
  • Custom pole layout, adapter plate, connector, or packaging is likely required.

Inquiry Email

[email protected]

Email app

Include workpiece details, target holding force, quantity, and destination.

Instant Chat

+86 18857971991

Direct RFQ discussion with our sales engineering team.