Solutions

Solutions & Applications

Select application scenarios to review magnetic gripping fit, workpiece risk, validation needs, and OEM support direction.

Each solution page is written for buyer-side decisions: what to validate first, where project risk usually appears, and what data should be included in the initial RFQ to avoid quote loops.

Application Selection Workflow

  1. Map the workpiece, pickup orientation, and automation cell.
  2. Define holding-force, release, and placement acceptance criteria.
  3. Match magnetic gripper type to workpiece material, surface condition, robot interface, and cycle requirements.
  4. Freeze prototype validation gates before PO release.
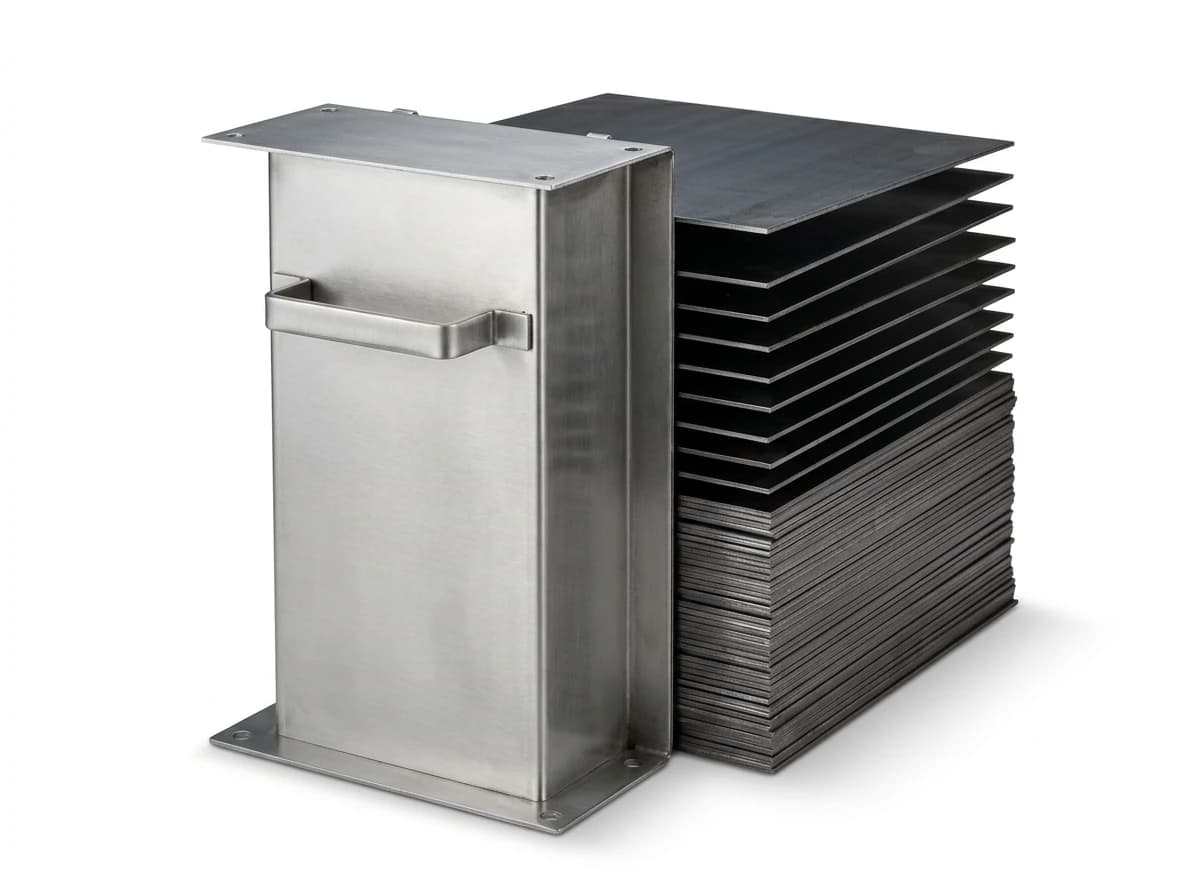
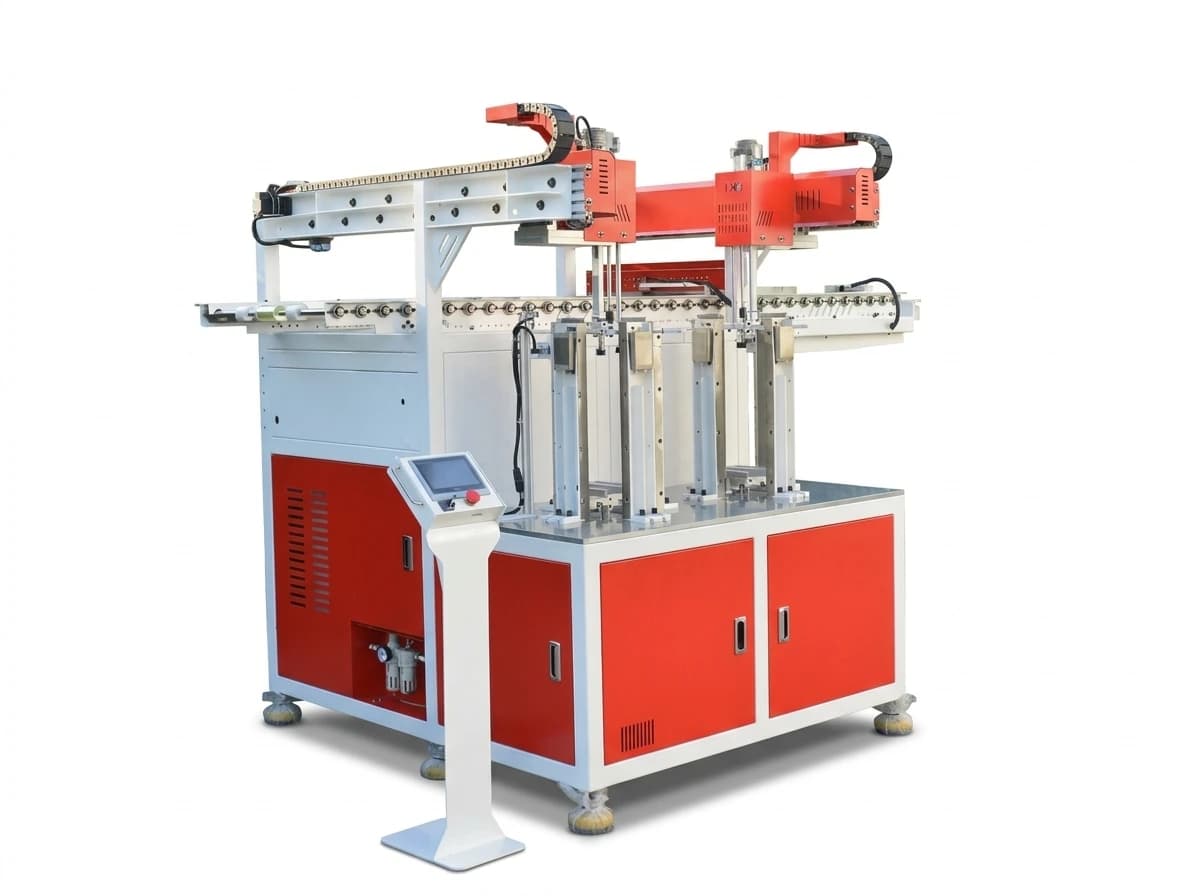
Permanent magnetic sheet fanner separator for sheet metal handling lines

Sheet Metal Handling

Magnetic gripping support for steel sheet, blanks, plates, and flat ferromagnetic parts.

For manufacturing engineers and integrators building sheet metal transfer cells.

  • Review sheet thickness, flex, coating, oil, and burrs
  • Support single or multi-magnet EOAT concepts
  • Useful when vacuum sealing or mechanical clamping is unstable
View details
Pneumatic magnetic gripper for stamping press feeding automation

Stamping Press Feeding

Magnetic gripper review for feeding, transferring, and unloading stamped steel blanks or parts.

For stamping lines, press automation integrators, and OEM equipment builders.

  • Press clearance and timing review
  • Stack separation and oil condition checks
  • Custom EOAT for transfer arms or robots
View details
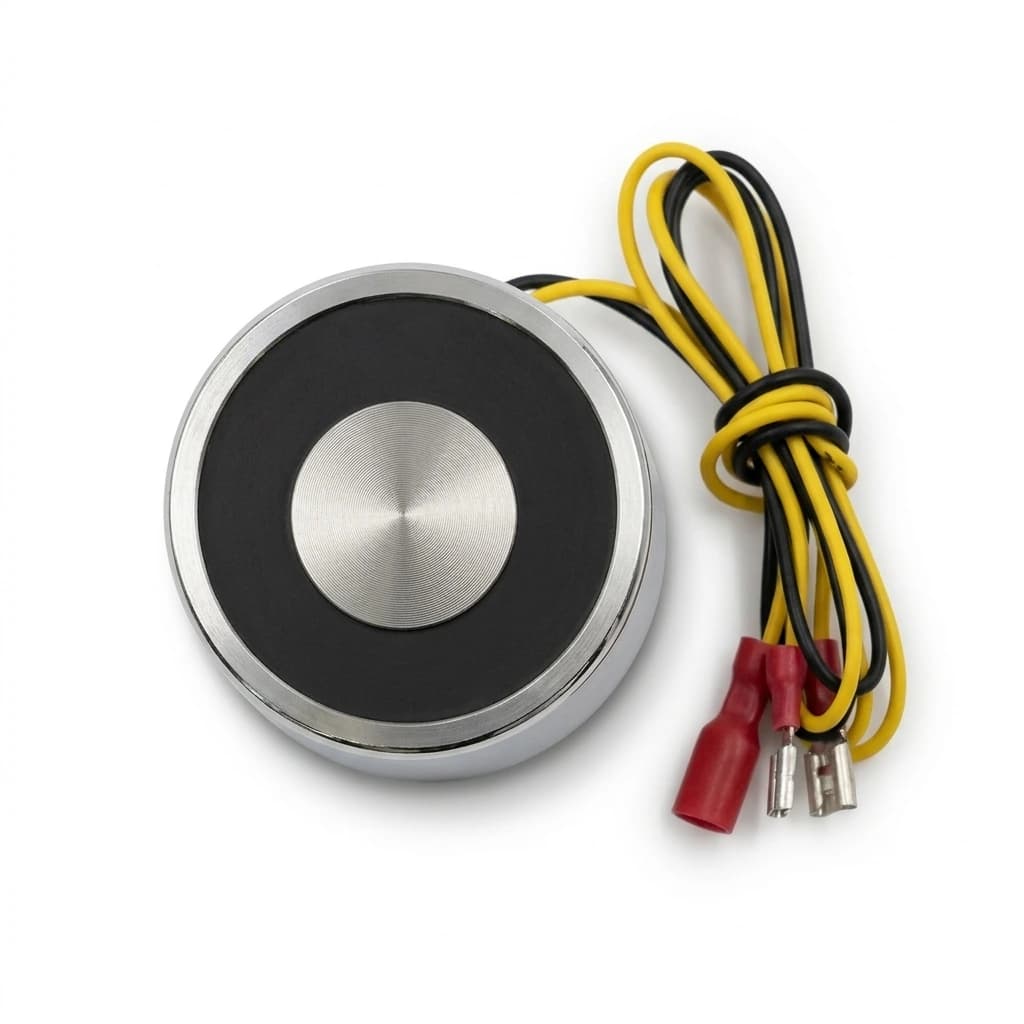
Robot magnetic gripper for pick-and-place automation

Robot Pick-and-Place

Magnetic gripping for robot transfer of steel parts where contact pickup can simplify tooling.

For robot integrators comparing magnetic gripping with vacuum, clamp, or mechanical finger tools.

  • Robot payload and motion review
  • Workpiece center-of-gravity checks
  • Custom mounting and cable routing
View details
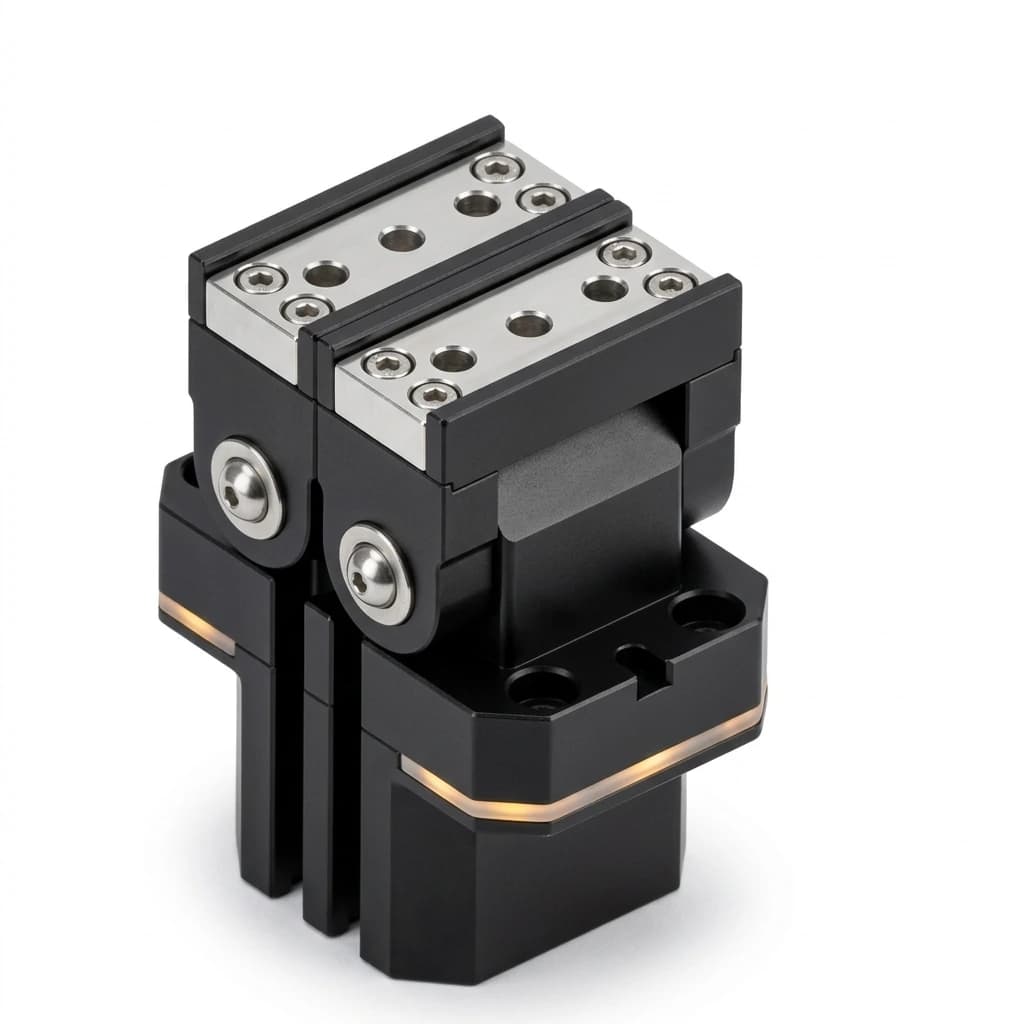
CNC machine tending dual magnetic gripper for automated lathe loading

Machine Tending

Magnetic gripping review for loading and unloading ferromagnetic parts in machine tending cells.

For automation teams adding robots or gantries to metal-part machine tending processes.

  • Compact tooling options for machine access
  • Release and placement review for fixtures
  • Electrical and cable interface planning
View details
Full layer magnetic depalletizer head for packaging lines

Palletizing and Depalletizing

Magnetic gripper concepts for moving ferromagnetic parts between pallets, trays, bins, and automation cells.

For integrators building metal-part material handling systems with changing stack presentation.

  • Review stack variation and pickup access
  • Support robot or gantry magnetic heads
  • Validate release and downstream placement
View details
Cobot magnetic gripper with ISO 9409 flange for collaborative handling

Cobot Handling

Magnetic tooling review for collaborative robot cells that handle ferromagnetic workpieces.

For teams using cobots where compact tooling, setup speed, and payload margin are important.

  • Low-mass tool design review
  • Simple mounting and cable planning
  • Workpiece validation for flexible cells
View details
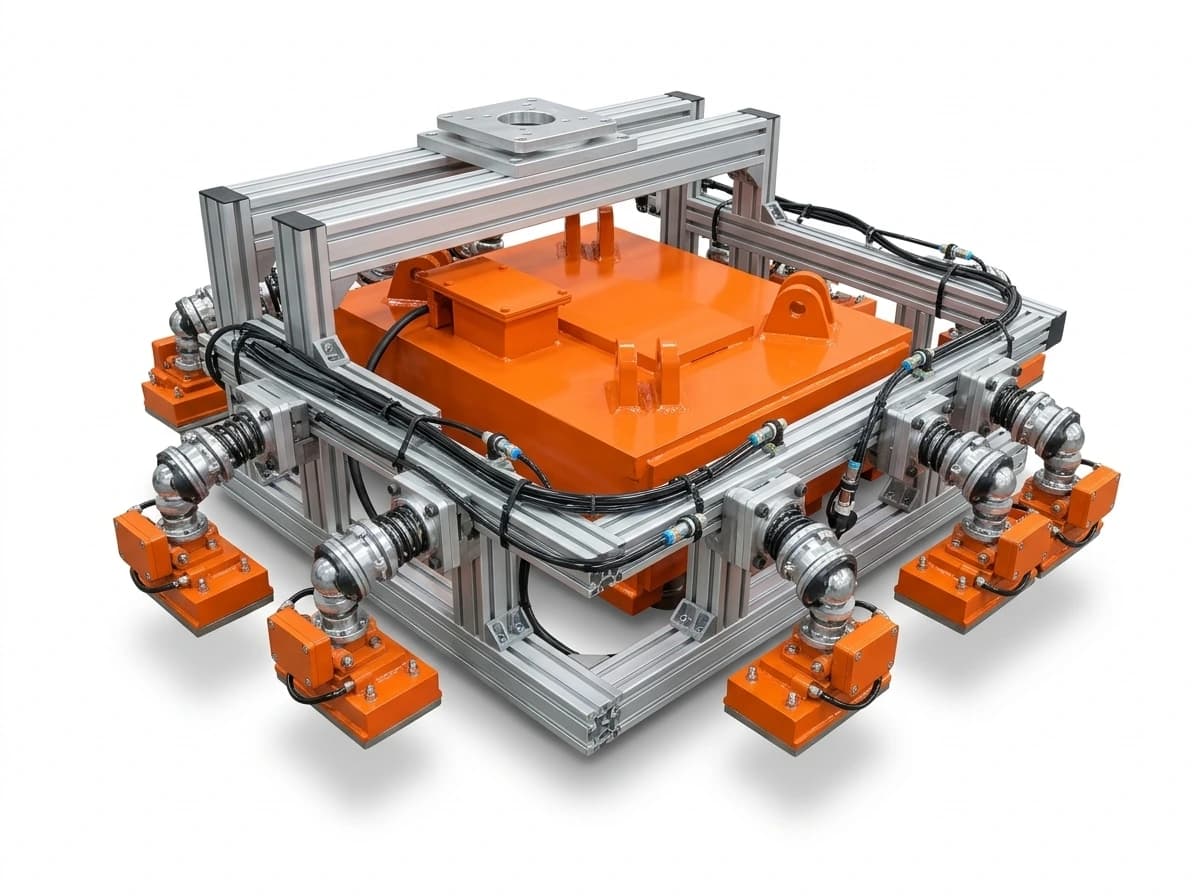
Custom automotive body stamping transfer frame with magnetic grippers

Automotive Automation

Magnetic gripping support for automotive metal-part transfer, handling, and line automation projects.

For automotive suppliers, integrators, and equipment builders handling ferromagnetic components.

  • Suitable for steel brackets, panels, blanks, and formed parts
  • Custom interface and process validation support
  • Batch repeatability and documentation planning
View details
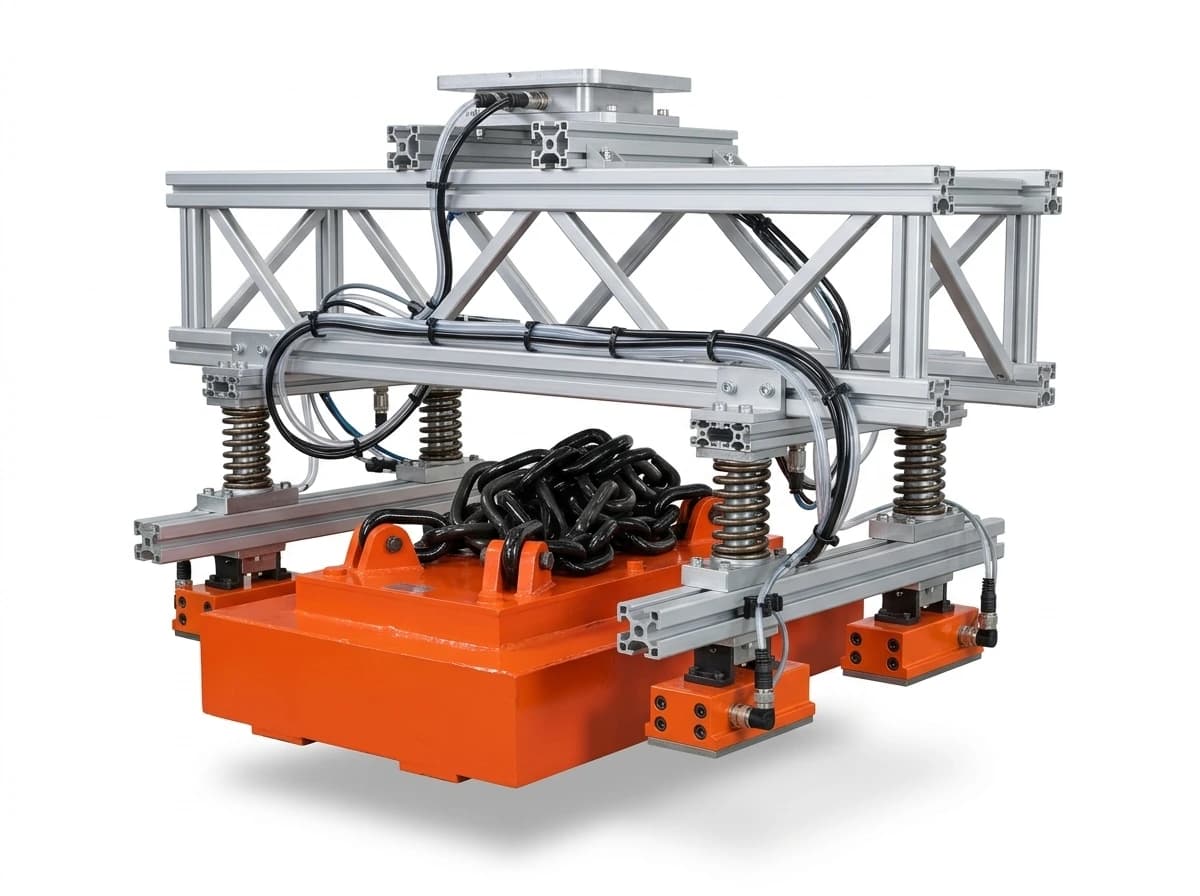
Custom aluminum truss frame magnetic EOAT integration

Custom EOAT Integration

Custom magnetic end-of-arm tooling support for robot cells, transfer systems, and OEM equipment.

For integrators and OEM teams with geometry, interface, or process constraints that standard grippers cannot solve.

  • Pole layout, bracket, and interface review
  • Controller, cable, connector, and installation planning
  • Sample-first validation before repeat production
View details

Solution Comparison Snapshot

SolutionPrimary Buyer FocusKey MetricWhy It Matters
Sheet Metal HandlingFor manufacturing engineers and integrators building sheet metal transfer cells.Sheet condition: Dry, oily, coated, burred, flexible, or stackedSheet condition directly affects grip reliability and release behavior.
Stamping Press FeedingFor stamping lines, press automation integrators, and OEM equipment builders.Press cycle integration: Reviewed against motion and clearance constraintsGripper geometry and release timing must fit the press process, not only the part.
Robot Pick-and-PlaceFor robot integrators comparing magnetic gripping with vacuum, clamp, or mechanical finger tools.Dynamic grip requirement: Estimated from motion profile and validated with samplesA static pickup test alone does not prove the cell can run at production motion.
Machine TendingFor automation teams adding robots or gantries to metal-part machine tending processes.Cell clearance: Reviewed from machine, robot, EOAT, and fixture drawingsCompact magnetic tooling must still avoid machine and fixture collisions.
Palletizing and DepalletizingFor integrators building metal-part material handling systems with changing stack presentation.Presentation variation: Defined by pallet, tray, bin, or stack dataThe magnetic head must tolerate realistic pickup variation, not only a single perfect sample.
Cobot HandlingFor teams using cobots where compact tooling, setup speed, and payload margin are important.Cobot payload margin: Reviewed with gripper, bracket, cable, and workpieceCobot payload limits leave less room for oversized tooling.
Automotive AutomationFor automotive suppliers, integrators, and equipment builders handling ferromagnetic components.Validation scope: Defined by sample parts and internal acceptance criteriaAutomotive projects usually need clear acceptance evidence before production release.
Custom EOAT IntegrationFor integrators and OEM teams with geometry, interface, or process constraints that standard grippers cannot solve.Interface completeness: Mechanical, electrical, control, validation, and packaging scopeCustom EOAT projects fail when interface ownership is left undefined.

Inquiry Email

[email protected]

Email app

Include workpiece details, target holding force, quantity, and destination.

Instant Chat

+86 18857971991

Direct RFQ discussion with our sales engineering team.